A dynamic positioning system (DP system or DPS) keeps a vessel on a set position and heading using its own thrusters and propellers. It replaces anchors where water is too deep or the seabed is too crowded. This guide explains how DP works, its main parts, the DP1, DP2, and DP3 classes, and the rules behind them.
What Is a Dynamic Positioning System?
A dynamic positioning system automatically holds a vessel’s position and heading without mooring lines or anchors. It measures where the vessel is, calculates the forces acting on it, and commands the thrusters to push back.
A vessel that holds station this way is a DP vessel. The US Coast Guard defines it as a vessel that maintains position and heading, or follows a target, automatically by means of its DP system.
DP controls the three horizontal motions: surge (forward and aft), sway (sideways), and yaw (heading). Roll, pitch, and heave are measured but not controlled, because thrusters cannot hold them.
How Does Dynamic Positioning Work?
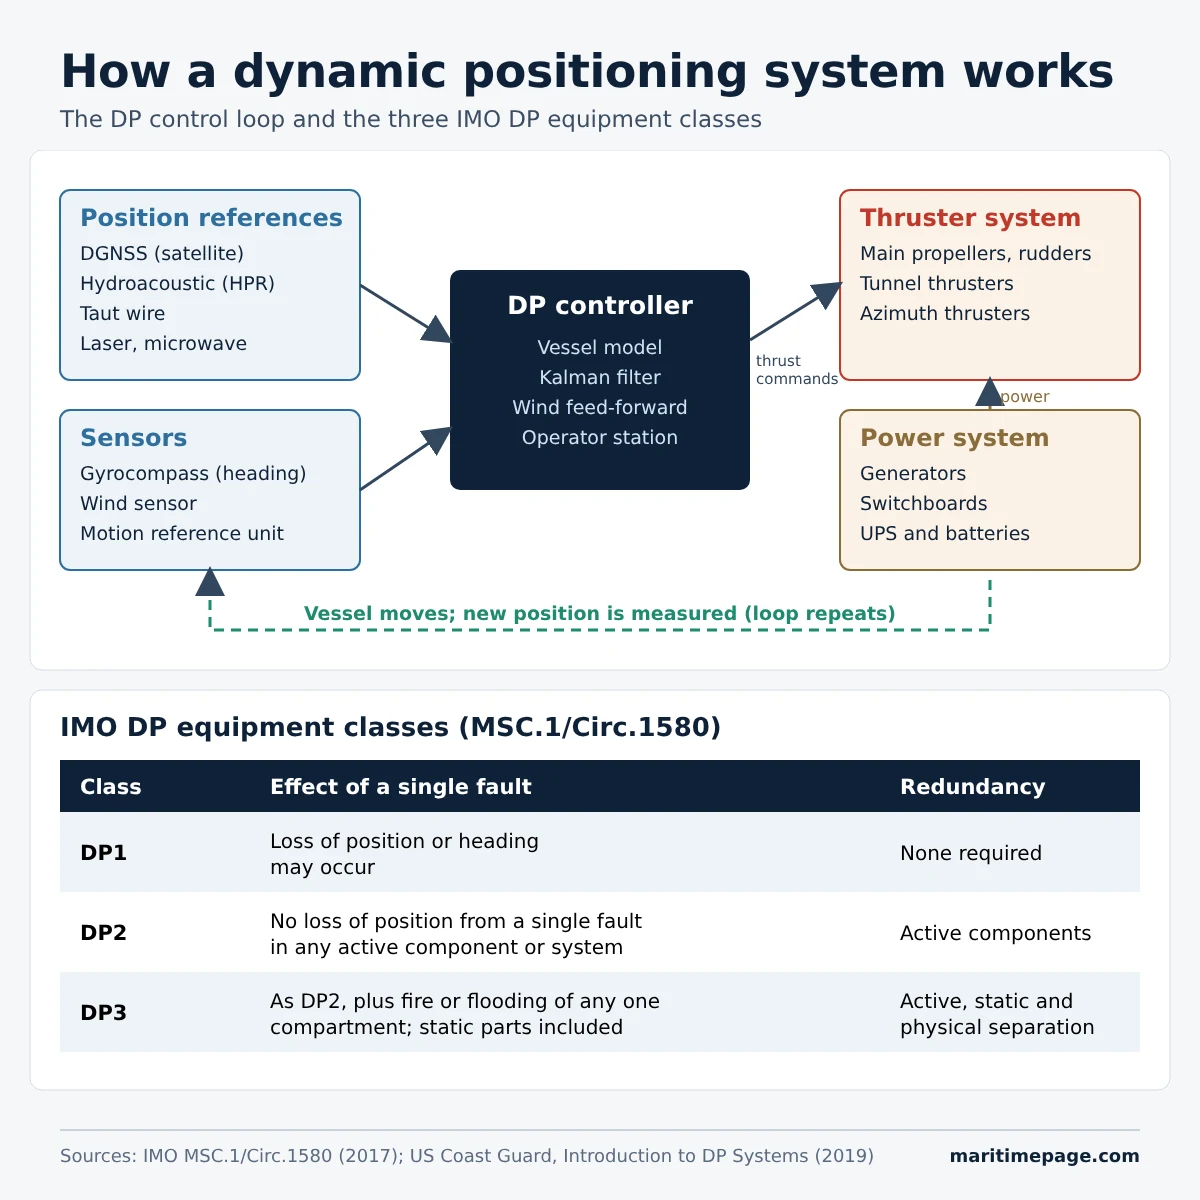
Dynamic positioning works as a closed control loop. Sensors and position references report where the vessel is, and the DP computer compares that with the set point. It then orders thrust to cancel the difference continuously.
- Measure: position reference systems give the vessel’s position, the gyrocompass gives heading, and wind and motion sensors report the conditions.
- Model: the DP computer runs a mathematical model of the vessel, its mass, drag and thruster response. A Kalman filter blends the model with the measurements.
- Anticipate: wind speed and direction are fed forward, so the system can counter a gust before the vessel moves off position.
- Act: the controller sets the pitch, speed, and direction of each thruster and propeller to produce the required force and turning moment.
- Keep going: if all position references drop out, the model can hold position for a short time by dead reckoning. How long depends on the model and the weather.
The DP operator chooses the mode. Options include holding a fixed position and heading, following a moving target such as an ROV, or tracking a planned route.

What Are the Main Components of a DP System?
A DP system has three parts under IMO guidelines: the power system, the thruster system and the DP control system. The control system includes the computers, operator stations, sensors and position reference systems.
Power system
The power system supplies the DP system with electricity. It covers the prime movers, generators, switchboards, and uninterruptible power supplies (UPS) with their batteries.
Thrusters draw most of that power, so a loss of generators can quickly become a loss of position. That is why redundant DP designs split the switchboard into separate sections. A full blackout, and how ships recover from it, is explained in what happens when a ship loses power.
Thruster system
The thruster system gives the DP system variable thrust in both force and direction. Typical units are main propellers with rudders, tunnel thrusters, and azimuth thrusters that rotate through 360 degrees.
DP control system
The control system is the hardware and software that turns measurements into thrust commands. It includes the DP computers, the operator stations and joysticks, and the networks that connect them.
Sensors
- Gyrocompasses for heading.
- Wind sensors for wind speed and direction, used for feed-forward.
- Motion reference units for pitch, roll, and heave, used to correct position readings.
Position reference systems
Position reference systems (PRS) tell the DP computer where the vessel is. Redundant systems run several at once and weight each by its accuracy.
| Type | Examples | What it measures |
|---|---|---|
| Satellite (absolute) | DGPS, DGNSS | Geographic position |
| Hydroacoustic (absolute) | HPR transponders on the seabed | Position relative to seabed beacons |
| Taut wire (relative) | Weighted wire lowered to the seabed | Angle of a wire to a fixed point below |
| Laser (relative) | Fanbeam, CyScan | Range and bearing to a reflector on a nearby structure |
| Microwave (relative) | RadaScan | Range and bearing to a transponder on a nearby structure |
What Are DP1, DP2 and DP3?
DP1, DP2 and DP3 are the three IMO DP equipment classes. They define how much redundancy a vessel has. Class 1 may lose position after a single fault; Class 2 and Class 3 must not.
| IMO equipment class | What a single fault can do | Typical notation (ABS / DNV / LR) |
|---|---|---|
| Class 1 (DP1) | Loss of position or heading may occur | DPS-1 / DYNPOS-AUT or DPS 1 / DP (AM) |
| Class 2 (DP2) | No loss of position from a single fault in any active component or system | DPS-2 / DYNPOS-AUTR or DPS 2 / DP (AA) |
| Class 3 (DP3) | No loss of position from any single fault, including fire or flooding in one compartment | DPS-3 / DYNPOS-AUTRO or DPS 3 / DP (AAA) |
Class wording follows IMO MSC.1/Circ.1580. The notation column is from the US Coast Guard’s DP reference guide (2019); check each society’s current rules for exact notation names.
Active components include generators, thrusters, switchboards, and communication networks. Static components, such as cables, pipes and manual valves, can be left out of the Class 2 single-failure analysis if they are adequately protected.
What Is the Difference Between DP2 and DP3?
DP3 adds protection against fire and flooding. A DP3 vessel must keep position even if every component in one watertight compartment or fire subdivision is lost. DP2 only covers a single fault in an active component or system.
- Physical separation: DP3 splits its redundant equipment into compartments separated by fire- and watertight boundaries. DP2 does not need this separation.
- Static components: in DP3, cables and pipes also count as possible single failures. In DP2, they can be excluded when protected.
- Typical use: the owner, charterer, or regulator chooses the class for the risk of the job. Work near a well, a manned platform, or divers usually calls for DP2 or DP3.
What Is a DP Vessel Used For?
DP vessels hold station for work that anchors cannot support: drilling, construction, diving support, cable and pipe laying, cargo transfer offshore and research.
- Drilling: drillships and semi-submersible offshore drilling rigs in deep water hold position over the well.
- Offshore support: platform supply vessels and anchor handling tug supply (AHTS) vessels hold station beside platforms and during rig moves.
- Construction and diving: crane vessels, diving support vessels and accommodation vessels (flotels).
- Cable and pipe laying: layers follow a planned track at slow speed while paying out cable or pipe.
- Offshore loading: shuttle tankers hold position while loading crude from a field’s storage unit.
- Dredging and rock dumping: dredgers and fall-pipe vessels follow precise tracks over the seabed.
- Research and survey: research vessels keep station over a sampling site or follow a towed instrument.
- Cruise ships: some cruise ships use DP to hold position off a port instead of anchoring.
How Is Dynamic Positioning Different From Anchoring?
Anchoring holds a vessel with chains and the seabed, while DP holds it with thrust. DP works in any water depth and moves instantly, but it burns fuel continuously and depends on power, thrusters and software.
| Factor | Dynamic positioning | Anchor spread |
|---|---|---|
| Water depth | No practical depth limit | Limited; deep water needs very long chain or wire |
| Setting up | Fast; no tugs needed | Slower; often needs anchor handling vessels |
| Seabed contact | None | Anchors and chain on the seabed, a risk near pipelines |
| Fuel | Continuous thruster load | Little or none once moored |
| Failure risk | Drift-off or drive-off after a fault | Anchor drag or line failure |
Deep-water mooring needs very long anchor chains or wire, which is one reason drilling moved to DP in deep water. In shallow water, a unit can instead stand on legs, like a jack-up rig or a lift boat.
What Rules and Guidelines Apply to DP Vessels?
The main international guidance is IMO MSC.1/Circ.1580, Guidelines for Vessels and Units with Dynamic Positioning Systems. It applies to vessels built on or after 9 June 2017. Older vessels may follow MSC/Circ.645 of 1994.
- FMEA: Class 2 and Class 3 vessels need a failure modes and effects analysis (FMEA). It shows how the system responds to each failure and is kept on board and up to date.
- Trials: proving trials confirm the FMEA. Annual trials, five-yearly periodic trials and special trials after repairs or incidents follow.
- Operating limits: an Activity Specific Operating Guideline (ASOG) sets the equipment and weather limits for each job. Drilling units use a Well Specific Operating Guideline (WSOG).
- Operating modes: Critical Activity Mode (CAM) is the set-up that delivers the vessel’s DP class. Task Appropriate Mode (TAM) applies when losing position would not be critical.
The flag state, or a classification society acting for it, approves the DP system and its FMEA. In the US, the Coast Guard uses the IMO circulars as guidance for plan review rather than as binding rules; see its DP regulatory guidance.
Industry guidance comes from the International Marine Contractors Association (IMCA) and the Marine Technology Society (MTS) DP Committee. IMCA, formed in 1995, publishes the IMCA M series on DP design, operation and personnel.
How Are DP Operators Trained?
The most widely held DP operator (DPO) certificate is issued by the Nautical Institute. The route combines an induction course, a simulator course and logged DP sea time on board, followed by competence sign-off. IMO training guidance is MSC.1/Circ.738/Rev.2.
- Initial certificate: induction and simulator courses and 120 DP sea time days across 12 task sections. A valid certificate of competency and company sign-off complete it, within four years.
- Revalidation: every five years, with 150 DP sea time days or a revalidation course, plus a competence assessment.
- Certificate types: unlimited, limited and unclassed, depending on the DP class of the vessels sailed on.
The Nautical Institute reports about 36,000 DPOs certificated worldwide and about 80 accredited training centres (figures from its 2023 scheme overview). IMCA M 117 sets training and experience levels for key DP personnel.
What Can Go Wrong in DP Operations?
The two main DP failures are drift-off and drive-off. Drift-off is a loss of position from partial or total loss of thrust. Drive-off is a loss of position caused by unwanted thrust from the DP system itself.
- Power loss: generator trips or a blackout remove thrust, causing drift-off.
- Faulty references: a wrong or jumping position signal can make the controller push the vessel away, causing drive-off.
- Human error: wrong mode selection, set-up or response, which is why ASOGs and drills exist.
- Environment: wind, waves or current beyond the vessel’s thrust capability.
Redundancy, the FMEA, trials and the ASOG all exist to keep a single failure from becoming a loss of position. Operators drill the response so the crew can stop the work and move clear safely.
Can Small Boats Use Dynamic Positioning?
Yes, in a simplified form. Many recreational outboard and pod-drive packages offer GPS “virtual anchor” or station-keeping modes. They are not IMO DP systems and carry no DP class or redundancy requirements.
These systems use GPS, an electronic heading sensor and joystick control of each engine. Examples include Mercury Skyhook, Yamaha Set Point and SeaStar SeaStation. Some hold only position and let the bow swing; others also hold heading.
How Big Is the Dynamic Positioning System Market?
One market estimate puts the global DP system market at about US$6.36 billion in 2025, rising to about US$8.65 billion by 2030. That is a compound annual growth rate of 6.3%.
The figures come from a 2025 report by Research and Markets, also published by MarketsandMarkets. Market reports use different scopes, so other estimates differ.
Who Makes Dynamic Positioning Systems?
Market reports name Kongsberg Maritime (Norway), Wärtsilä (Finland), GE Vernova (US) and ABB (Switzerland) among the main DP system suppliers. Smaller specialists, such as Navis Engineering of Finland, also supply DP control systems.
Rolls-Royce’s commercial marine business, including its DP products, became part of Kongsberg in April 2019. Older references to Rolls-Royce DP systems now point to Kongsberg.
When Was Dynamic Positioning First Used?
Dynamic positioning dates from 1961. That year the drilling vessel CUSS 1 held position with steerable propellers for Project Mohole. Shell’s Eureka became the first vessel with automatic position control.
Eureka used an analogue controller and a simple taut wire. The first purpose-built DP drillship, SEDCO 445, followed in 1971. Satellite positioning later made DP practical for many more vessels.
Related Topics
- The ISM Code: the safety management system that holds a company’s operating procedures, including DP procedures.
- Cruise ship stabilizers: how fins and gyros reduce roll, a motion DP does not control.
- How to become an oil rig worker: routes into offshore work, including on DP units.
What is a dynamic positioning system?
It is a computer-controlled system that holds a vessel on a set position and heading with its own thrusters. It needs no anchors or mooring lines.
How does dynamic positioning work?
Position references and sensors measure the vessel’s position, heading and the wind. The DP computer compares this with the set point and commands the thrusters to cancel any difference.
What is a DP vessel?
A DP vessel is a ship or offshore unit that holds position automatically with a DP system. Examples include drillships, offshore supply vessels, diving support vessels, shuttle tankers and cable layers.
What is the difference between DP1, DP2 and DP3?
A DP1 vessel may lose position after a single fault. A DP2 vessel must not lose position after a single fault in an active component. A DP3 vessel must also survive fire or flooding in one compartment.
What does DPS mean in shipping?
DPS stands for dynamic positioning system. ABS also uses DPS-1, DPS-2 and DPS-3 as its class notations for the three IMO DP equipment classes.
What position reference systems does DP use?
Common references are DGNSS satellite positioning, hydroacoustic systems, taut wires, and laser or microwave systems that measure range to a nearby structure. Redundant systems use several at once.
What is a disadvantage of DP compared with anchoring?
DP burns fuel continuously and depends on power, thrusters and software. A fault can cause drift-off or drive-off, so redundancy, trials and trained operators are needed.
Who certifies DP operators?
The most widely held DPO certificate is issued by the Nautical Institute. It requires induction and simulator courses, logged DP sea time and competence sign-off, and is revalidated every five years.

- What Is a Jack-Up Rig? Legs, Preloading and Punch-Through Explained – October 31, 2026
- Great Lakes Maritime Academy: Programs, Cost and Admission – October 14, 2026
- Bunker Delivery Note (BDN): Contents, MARPOL Rules and Checks – October 11, 2026